Developers
SDKs, ROS 2 packages and guides for ARX hardware. Everything below is open source on GitHub.
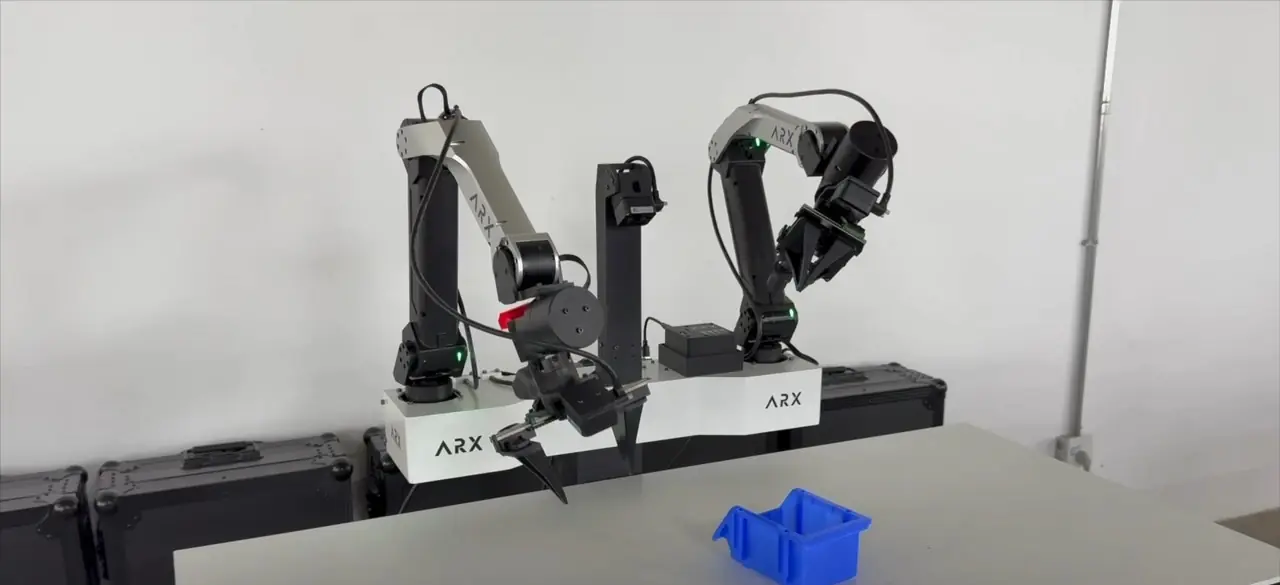
Collect, train, deploy: ARX's ROS 2 imitation-learning pipeline
How ARX's ROS 2 pipeline records demonstrations, trains an ACT-based policy and deploys it on AC one, LIFT2s and X7s: supported systems, ope…
Read →
ARX X5 Python quickstart with arx5-sdk
Install arx5-sdk with pip, bring up a USB-CAN or EtherCAT-CAN adapter, and run joint control, keyboard and SpaceMouse teleoperation, teach a…
Read →At a glance
| Languages | Python and C++ |
|---|---|
| Without ROS | arx5-sdk (X5); ARX Python SDKs for X5 and A5 |
| ROS | R5 has ROS and ROS 2 workspaces |
| Data pipeline | ROS 2 only: Jazzy on Ubuntu 24.04 (recommended) or Humble on 22.04 |
| Bus | CAN via USB-CAN or EtherCAT-CAN adapters, bound with udev rules |
| Cameras | Intel RealSense D405, USB 3, at most two per hub |
| Teleoperation | Leader arms, VR (Meta Quest 3), keyboard, SpaceMouse |
| Imitation learning | Open-source pipeline migrated from ACT |
Repositories
github.com/ARXroboticsX →| Repository | What it is | Language |
|---|---|---|
| ARX_X5 | X5 and AC one control SDK | C++ |
| X5 | X5 Python SDK | C++/Python |
| R5 | R5: ROS, ROS 2, Python, VR SDK | C++ |
| A5 | A5 Python SDK | C++/Python |
| LIFT | LIFT control SDK | C++ |
| X7s | X7s control SDK | |
| ROS2_AC-one_Play | AC one imitation learning (ROS 2) | Python |
| ROS2_LIFT_Play | LIFT imitation learning (ROS 2) | Python |
| ROS2_X7s_Play | X7s imitation learning (ROS 2) | Python |
| ARX_VR | VR teleoperation, Meta Quest 3 | |
| ARX_PLAY | ALOHA data collection for R5 and X7 | Python |
| ARX_Model | Robot models | CMake |
| ARX_all_in_one_readme | Manuals: collect–train–deploy, CAN, motor calibration | |
| arx5-sdk | Stanford REAL Lab: Python and C++ controller for X5 (pip install arx5-interface) | C++/Python |
Developer questions
Do ARX arms work with ROS 2?
Yes. ARX's collect–train–deploy pipeline runs on ROS 2 (Jazzy on Ubuntu 24.04, Humble on 22.04), and the R5 repository has ROS and ROS 2 workspaces.
Can I use ARX arms without ROS?
Yes. Stanford's arx5-sdk drives X5 from Python or C++ without ROS, and ARX publishes Python SDKs for X5 and A5.
How do I install the X5 Python SDK?
Run pip install arx5-interface (Stanford's arx5-sdk, x86_64 and aarch64, Python 3.8 to 3.14), set up your CAN adapter, then run the examples with the model name and CAN interface, for example X5 can0.
What computer do I need?
ARX recommends Ubuntu 24.04 with an NVIDIA graphics card for its data pipeline. Connect cameras to USB 3 ports, with at most two cameras per USB hub.
Which cameras does ARX use?
Intel RealSense D405 cameras on the head and wrists in ARX's data pipeline.
Is there VR teleoperation?
Yes. ARX publishes ARX_VR for Meta Quest 3 and documents VR teleoperation for X7s and LIFT2s.
Need help choosing a setup?
Tell us your software stack and we will confirm support before you order.