Blog
Guides and research notes on teleoperation, data collection, force control and choosing hardware for robot learning.
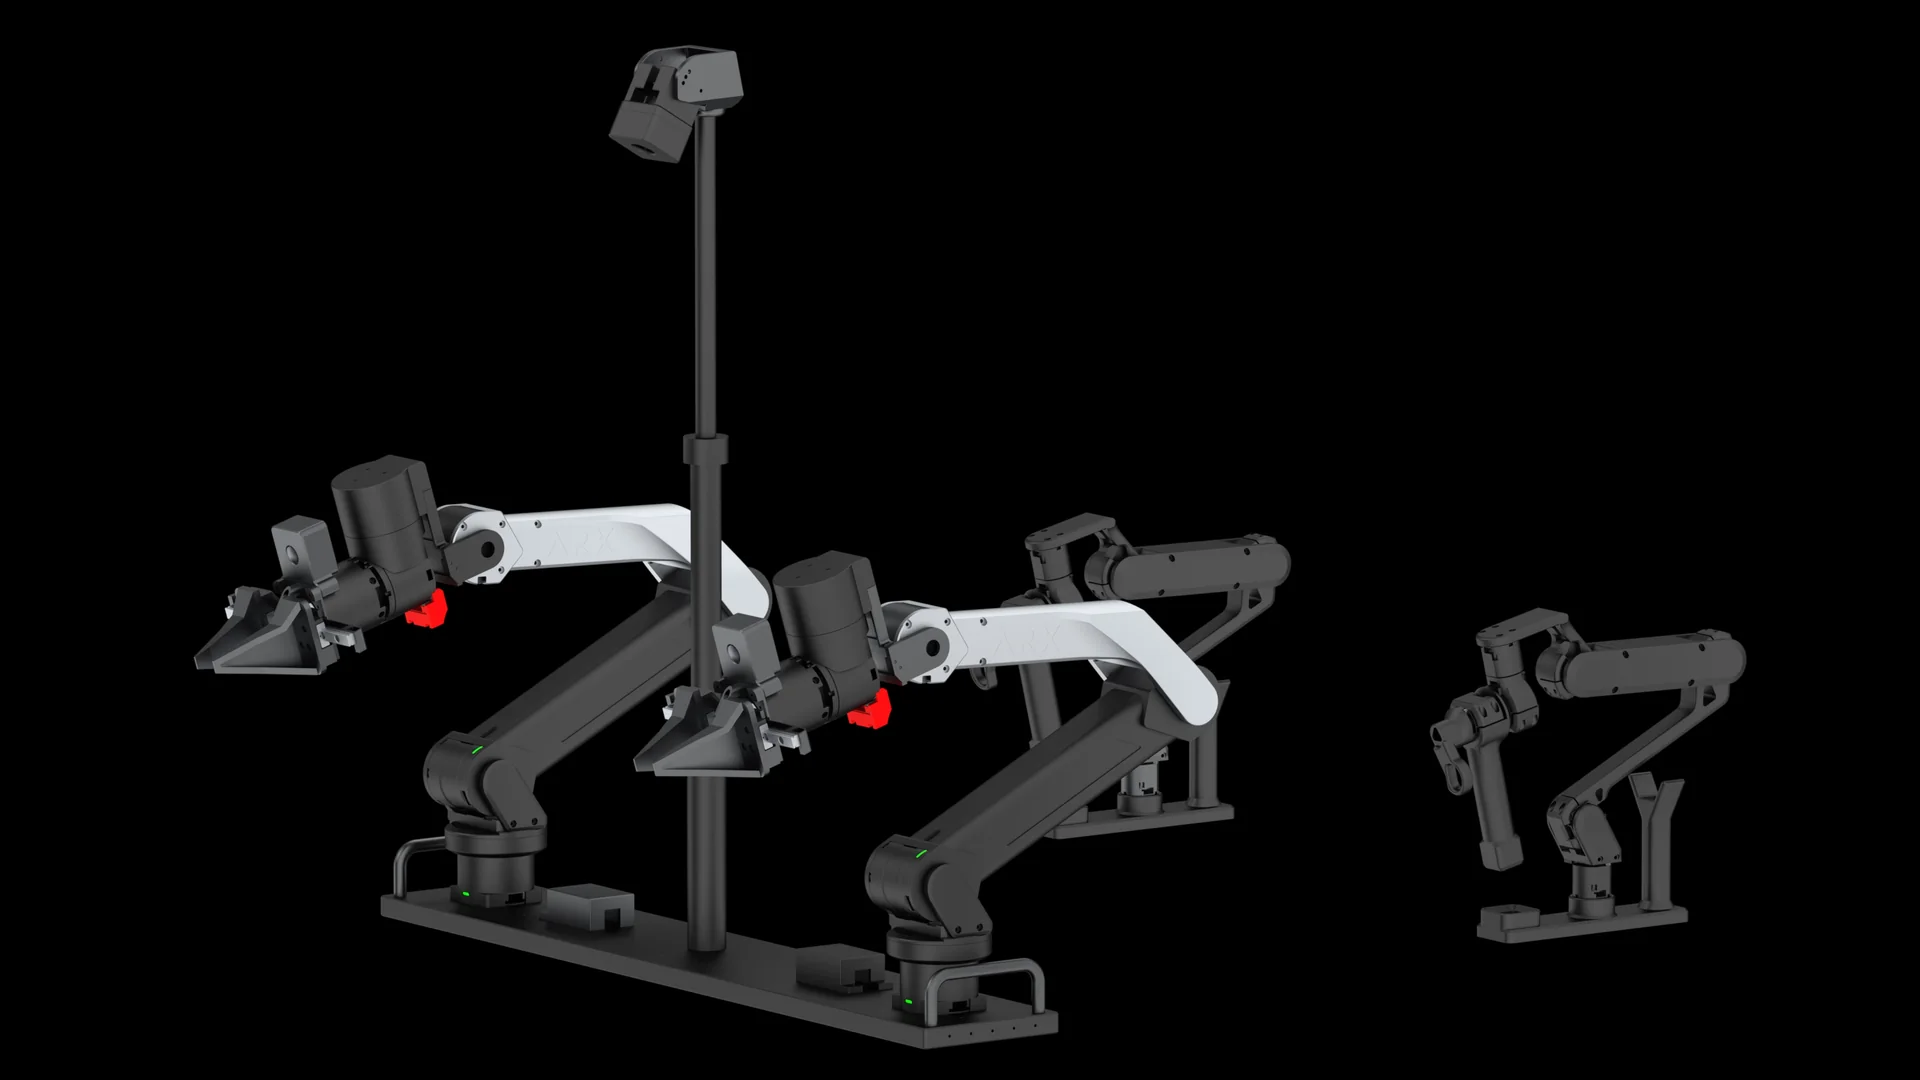
Choosing a robot arm for VLA research in 2026: X5, PiPER, WidowX AI and SO-101 compared
Published specs and list prices for four popular research arms, ARX X5, AgileX PiPER, Trossen WidowX AI and SO-101, and how to choose for imitation le…
Read →
Research built with ARX arms: 25 projects from 2024 to 2026
Robot learning projects that ran on ARX hardware, from π0 to Xiaomi-Robotics-1, grouped by topic, with the evidence for each.
Read →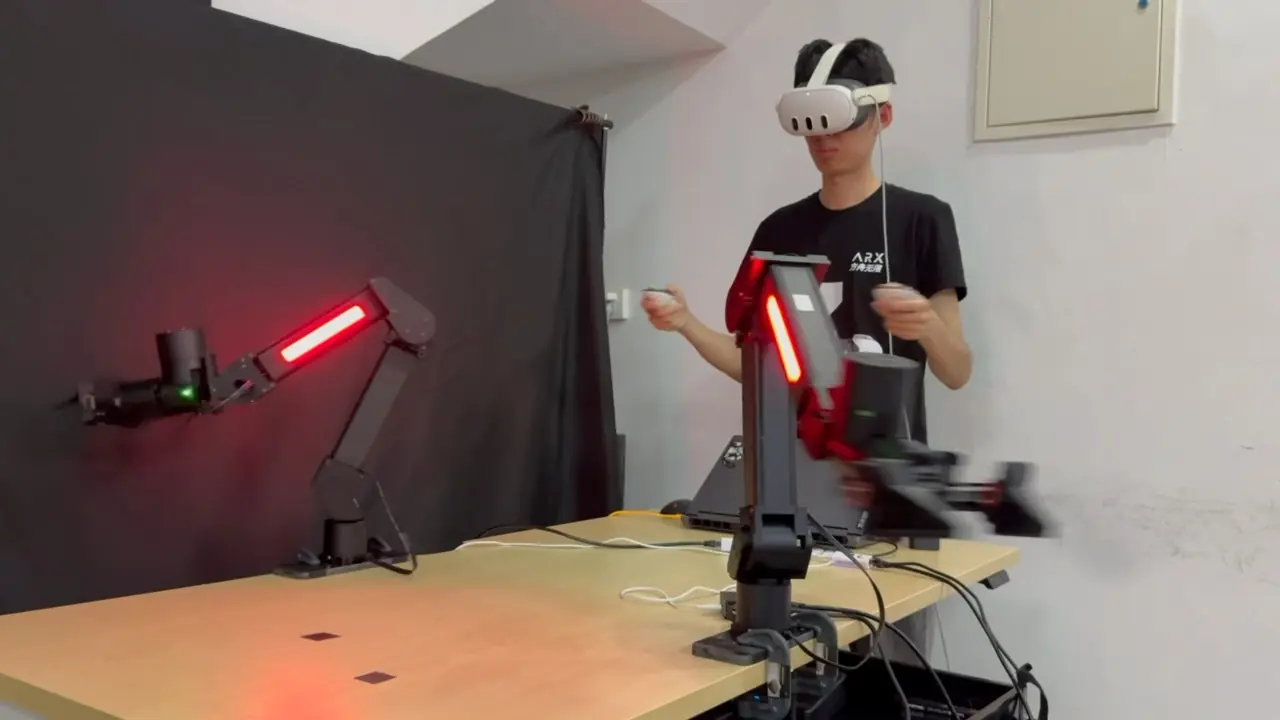
Leader–follower teleoperation: a practical guide for robot learning labs
What leader–follower teleoperation is, why imitation-learning labs use it, what hardware it needs, how it compares with VR and SpaceMouse control, and…
Read →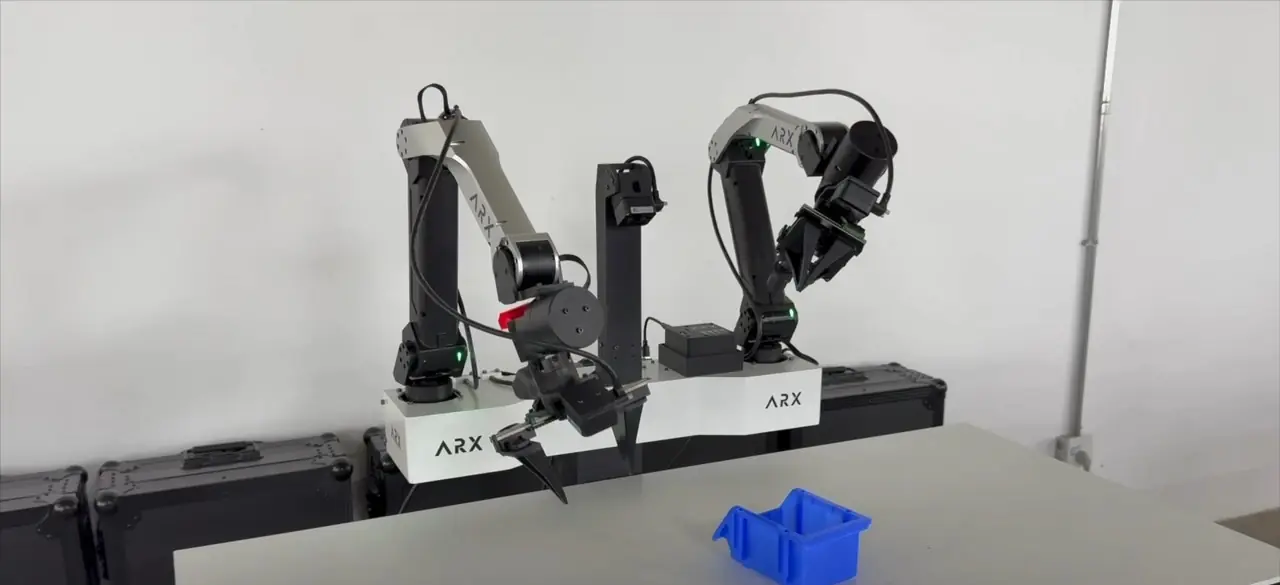
How to set up a bimanual data-collection station
A step-by-step checklist for a two-arm teleoperation station: arms, cameras, computer, CAN binding, camera mapping, and the collect–train–deploy loop,…
Read →
Why force control matters for imitation learning
What force-controlled and quasi-direct-drive arms change for teleoperation, data collection and policy deployment, and which control features to check…
Read →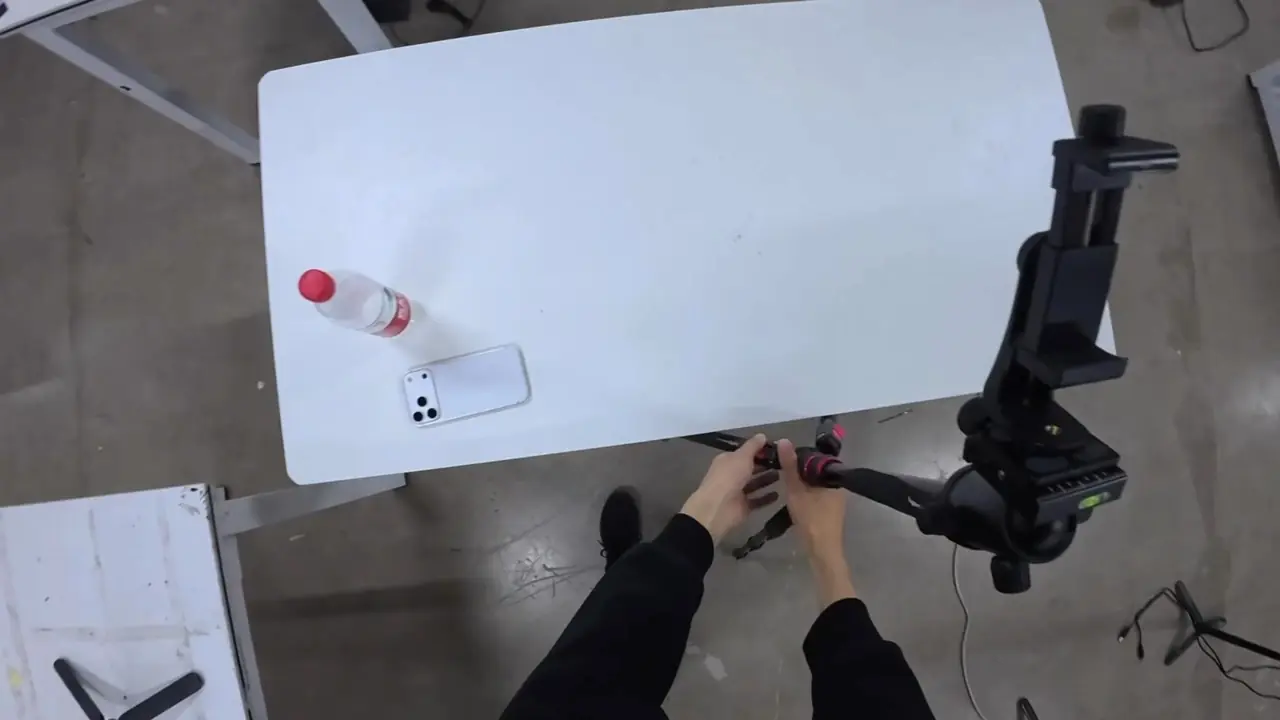
Egocentric data for robot learning: what recent work shows
What egocentric (first-person) human data is, what EgoVerse, EgoWAM, UMI and Xiaomi-Robotics-1 show about using it, and how to pair it with robot data…
Read →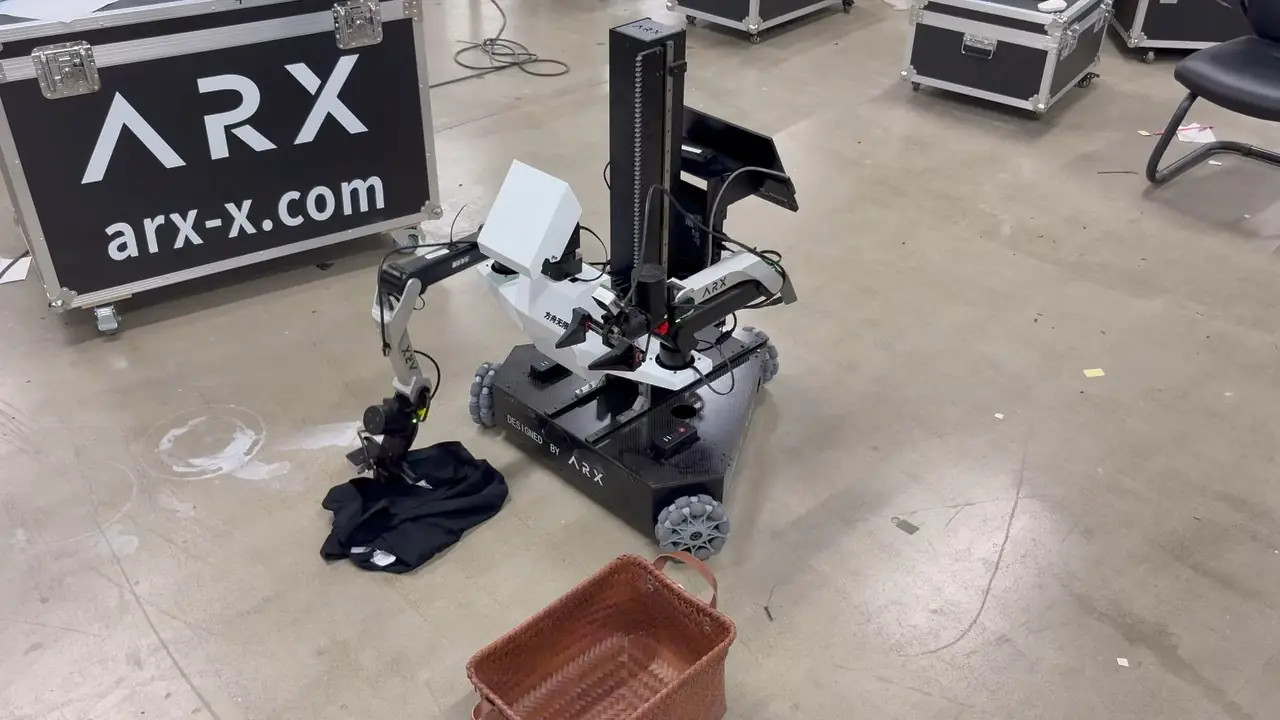
Mobile manipulation platforms for research: lift, head and base control explained
What a research mobile manipulator needs (a base you can drive from code, a lift, a movable head camera, VR teleoperation and the same data pipeline a…
Read →Get a price for your setup.
Price, lead time and shipping options for your country.